Four technical pillars driving our multisensory VR motion platform.
Research & Experimental Data
Access comprehensive telemetry logs, sensor calibration scripts, and participant evaluation metrics from our physical VR flight trials.
Raw hardware sensor telemetry, real-time actuator response timings, and embedded communication logs.

Empirical human-participant evaluation records, subjective presence questionnaires, and latency benchmarking trials.
Addressing common questions regarding our hardware architecture, safety constraints, and experimental findings.

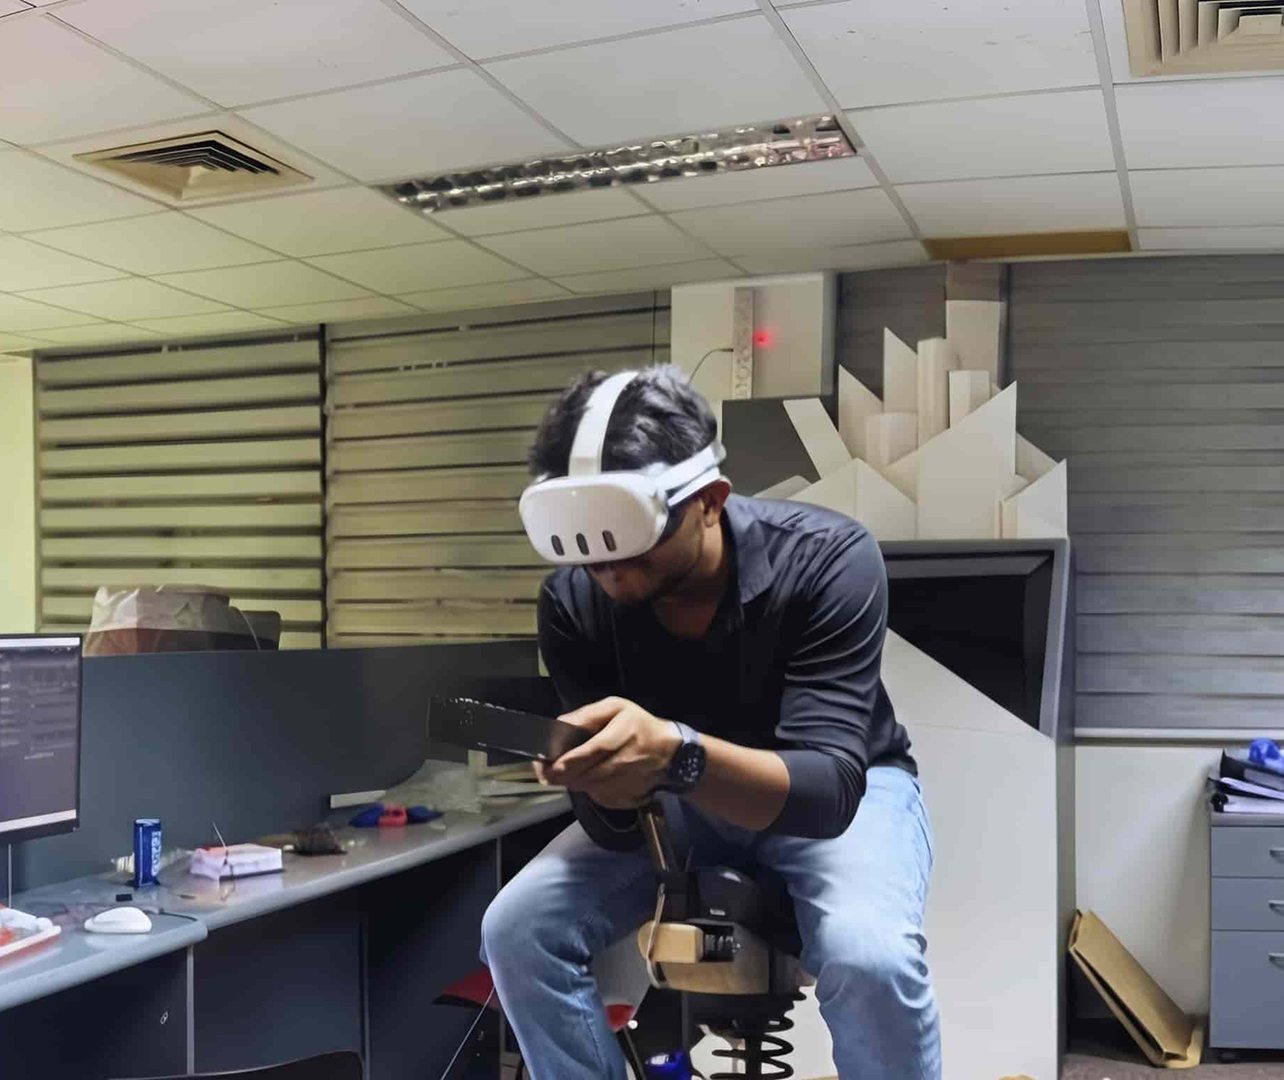
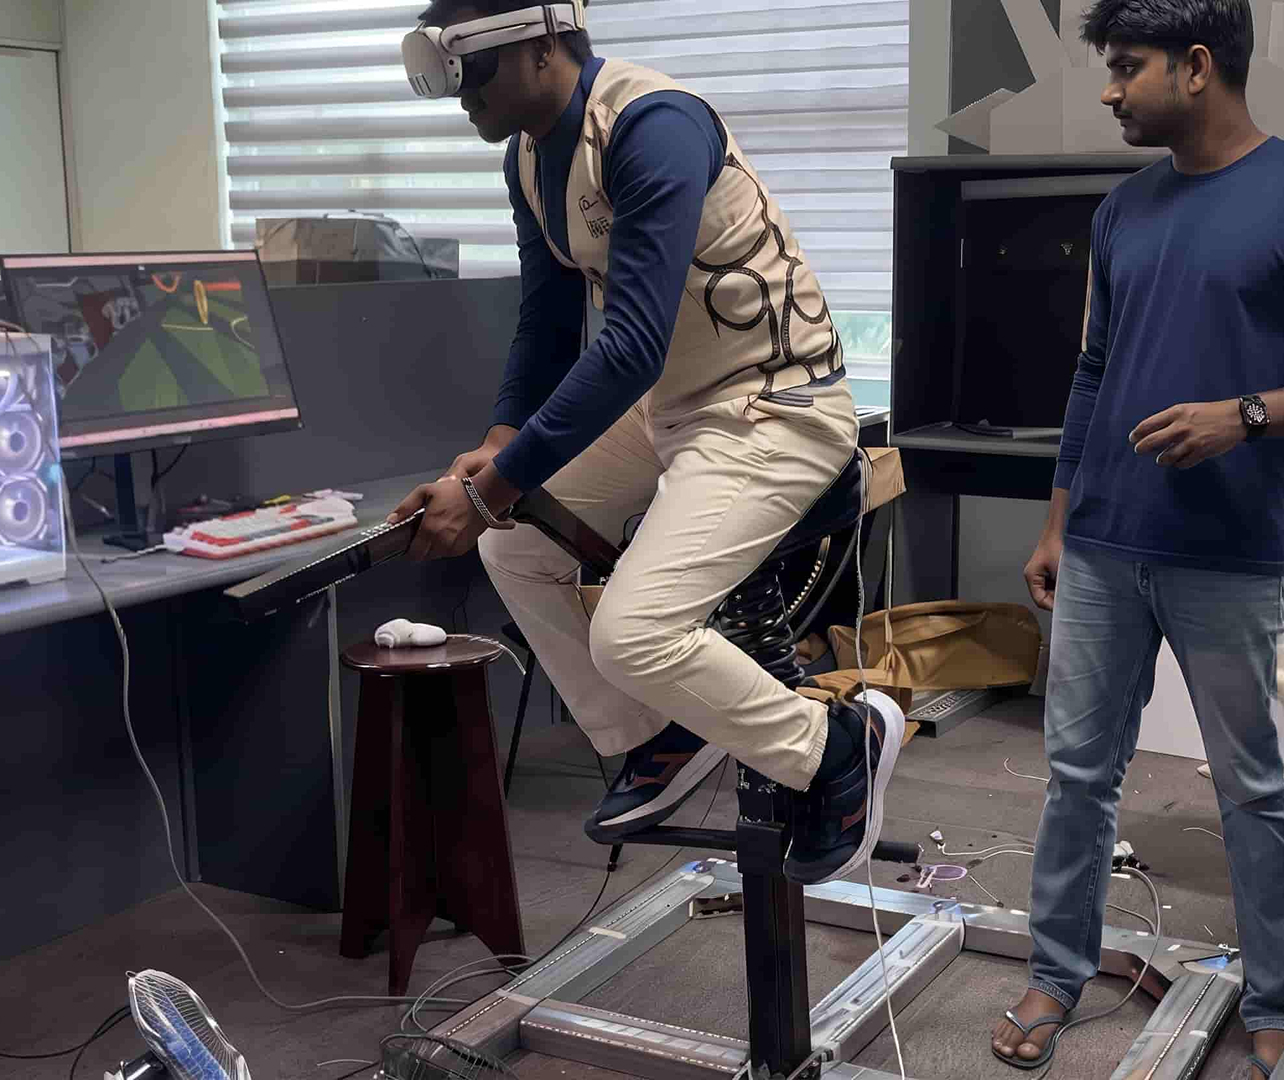
Moving in VR without physical sensations causes sensory mismatch and motion sickness. The platform resolves this by pairing visual flight with real-time seat tilt, variable airflow, and localized haptic cues to maintain bodily coherence.
Gyroscope and pressure sensors capture body-lean tilt and handle compression, directly driving pitch, roll, and flight velocity without relying on traditional joysticks.
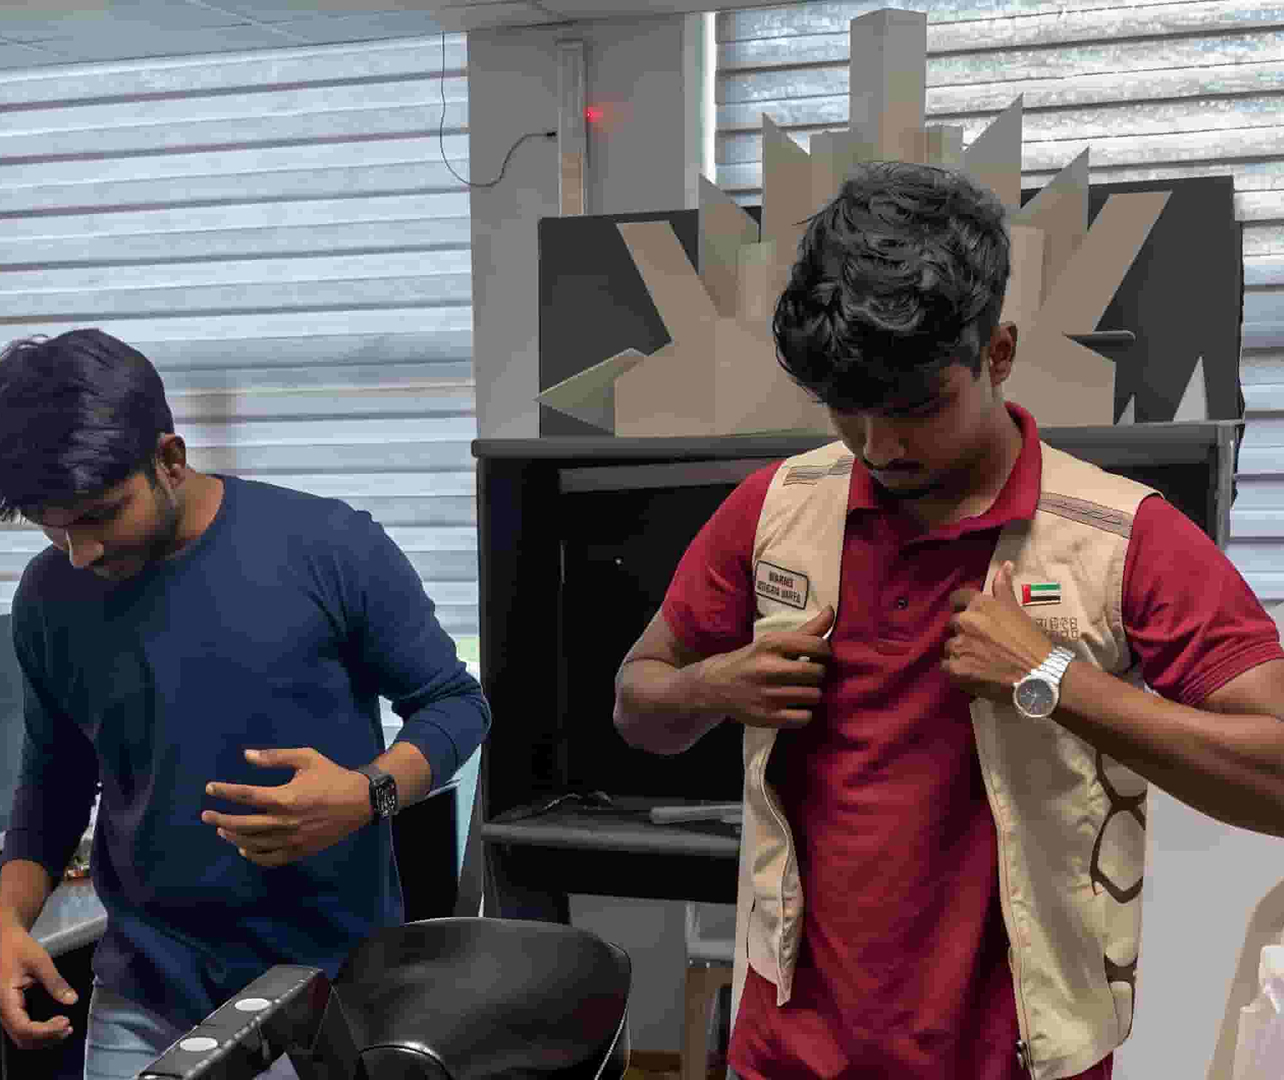
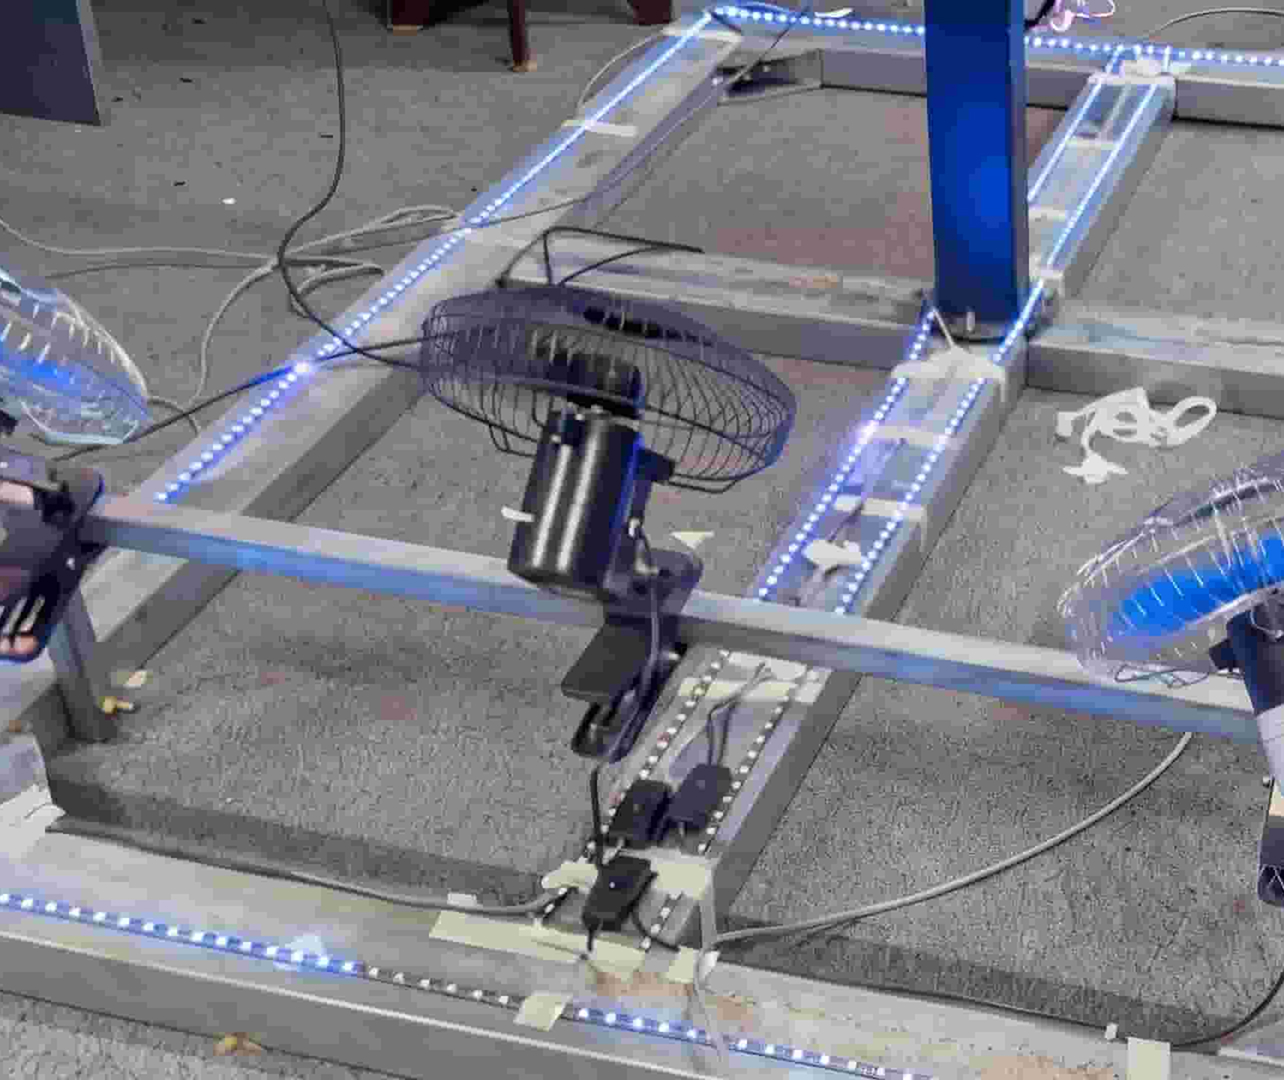
Environmental states in Unity trigger variable airflow blowers, directional wind currents, and vibrotactile vest pulses to recreate ambient flight forces.
The navigation architecture applies strict deadzone threshold filtering to tilt-to-turn inputs, separating deliberate body-lean maneuvers from involuntary movements to maintain stable heading control.